Texas Humanoid
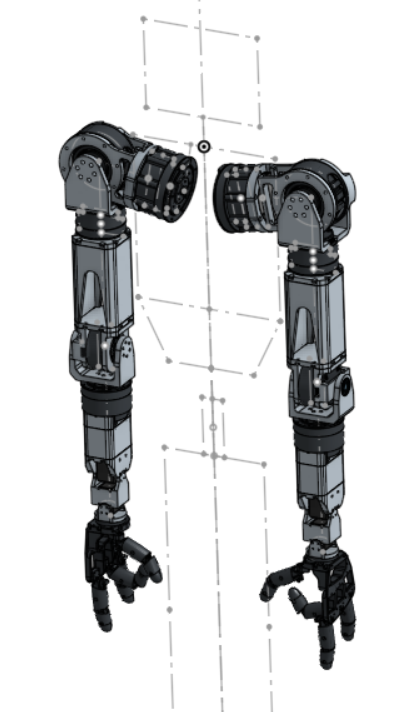
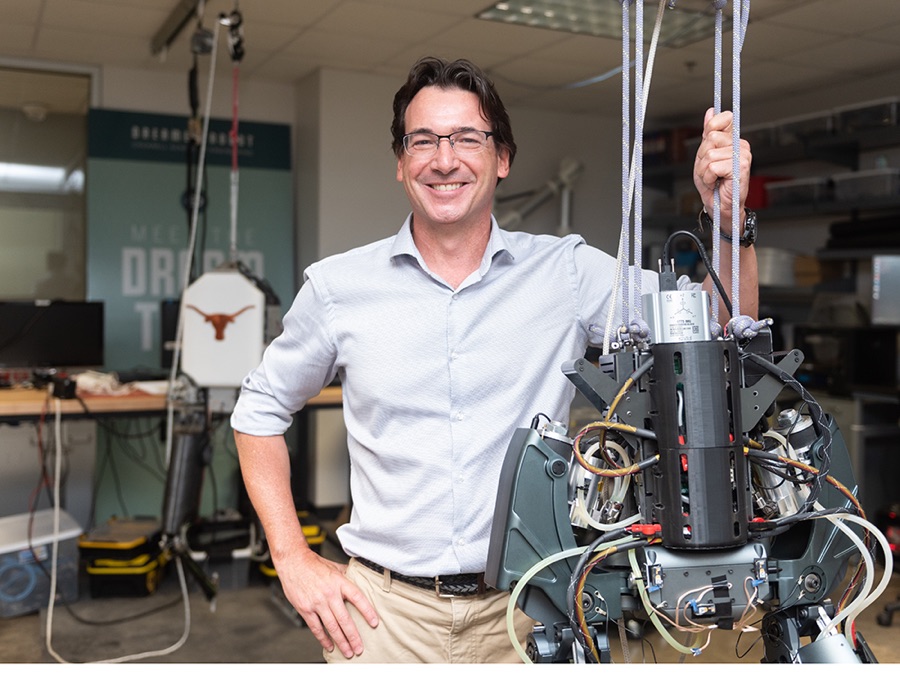
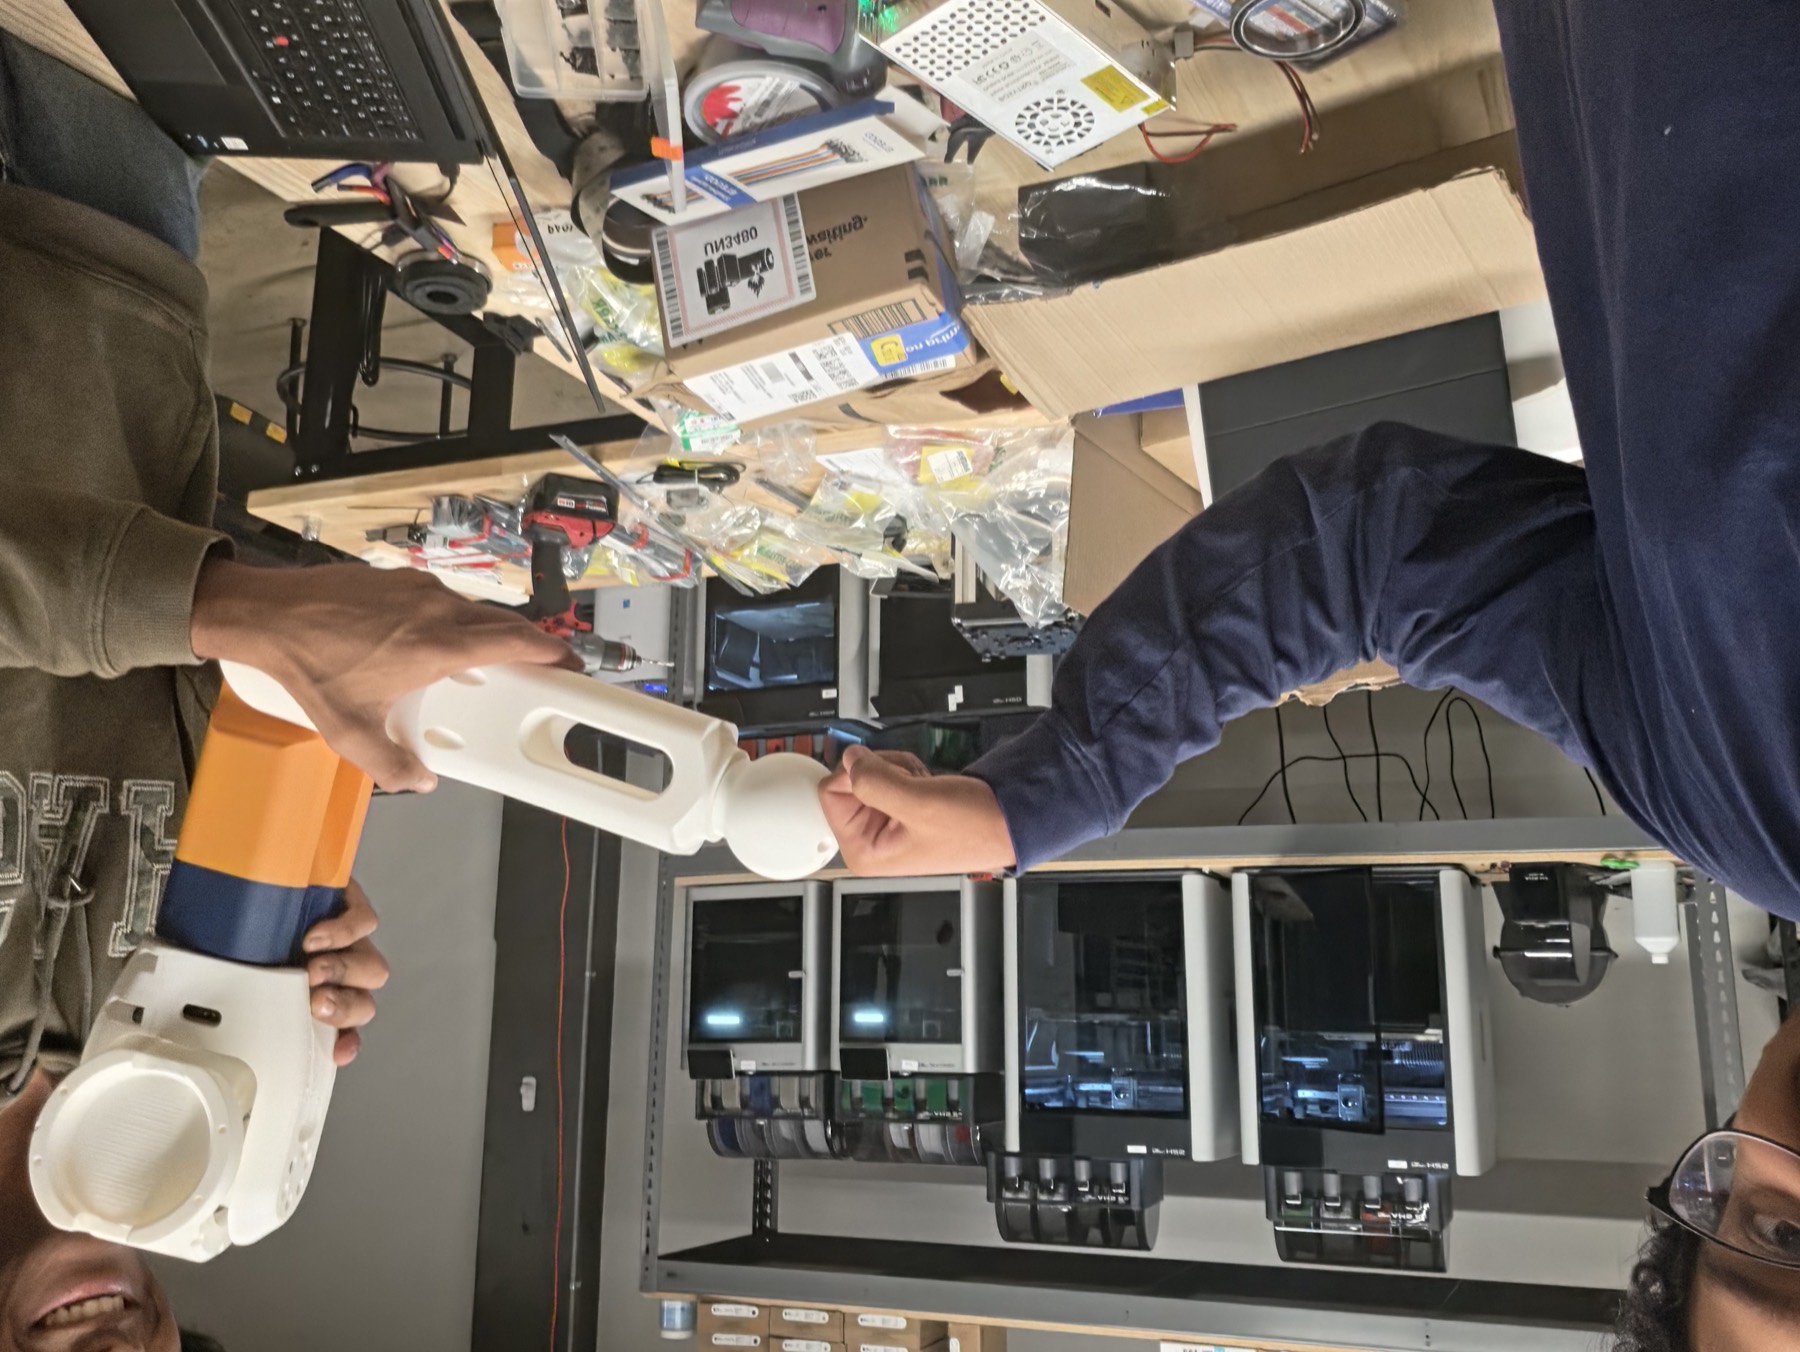
In-house · Open sourceUT Austin's first open-source humanoid. Built in-house as a baseline platform for specialized research in robotics labs, with actuators, electronics, simulation and controls developed from scratch.
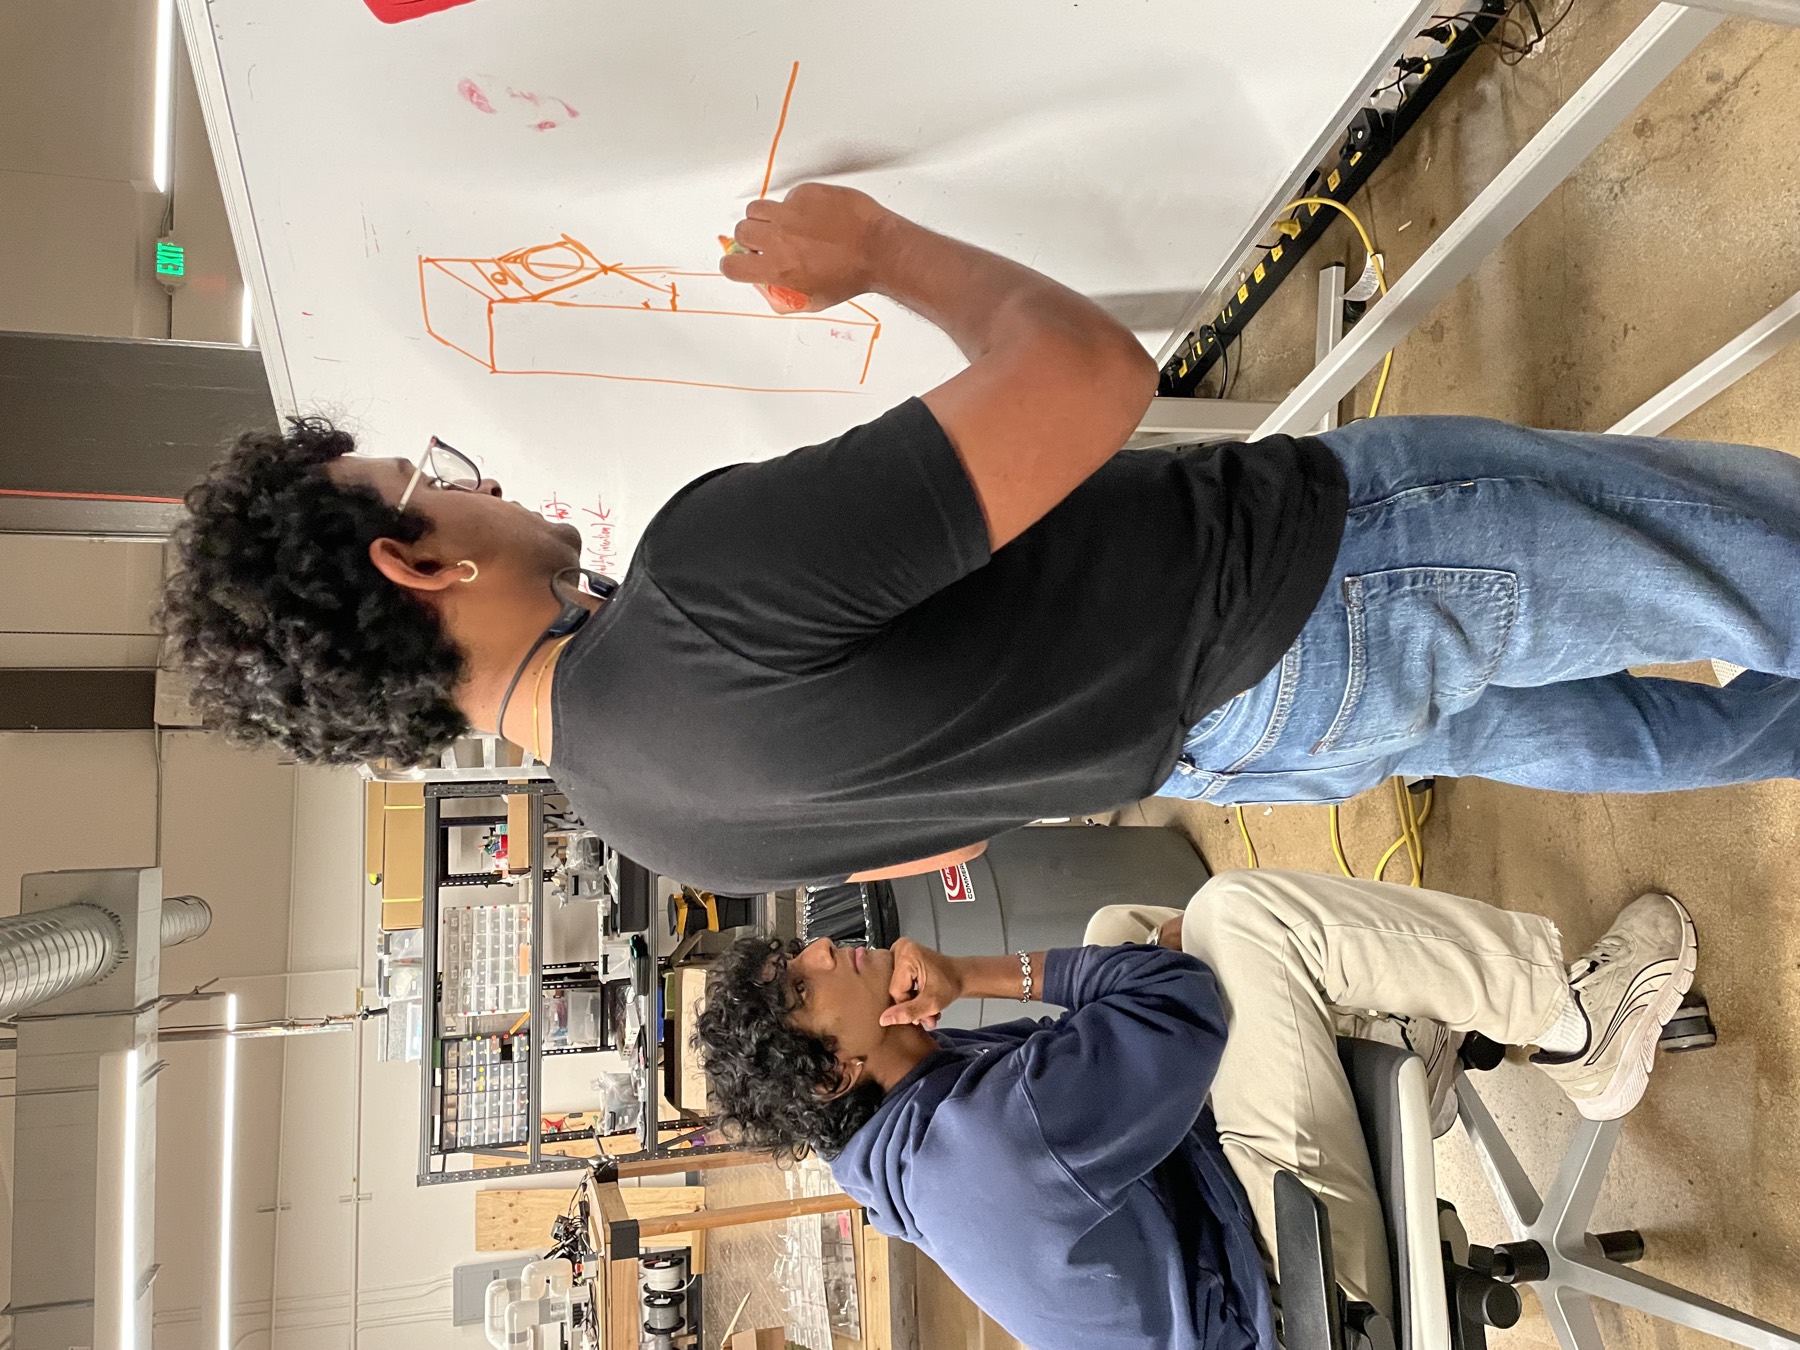
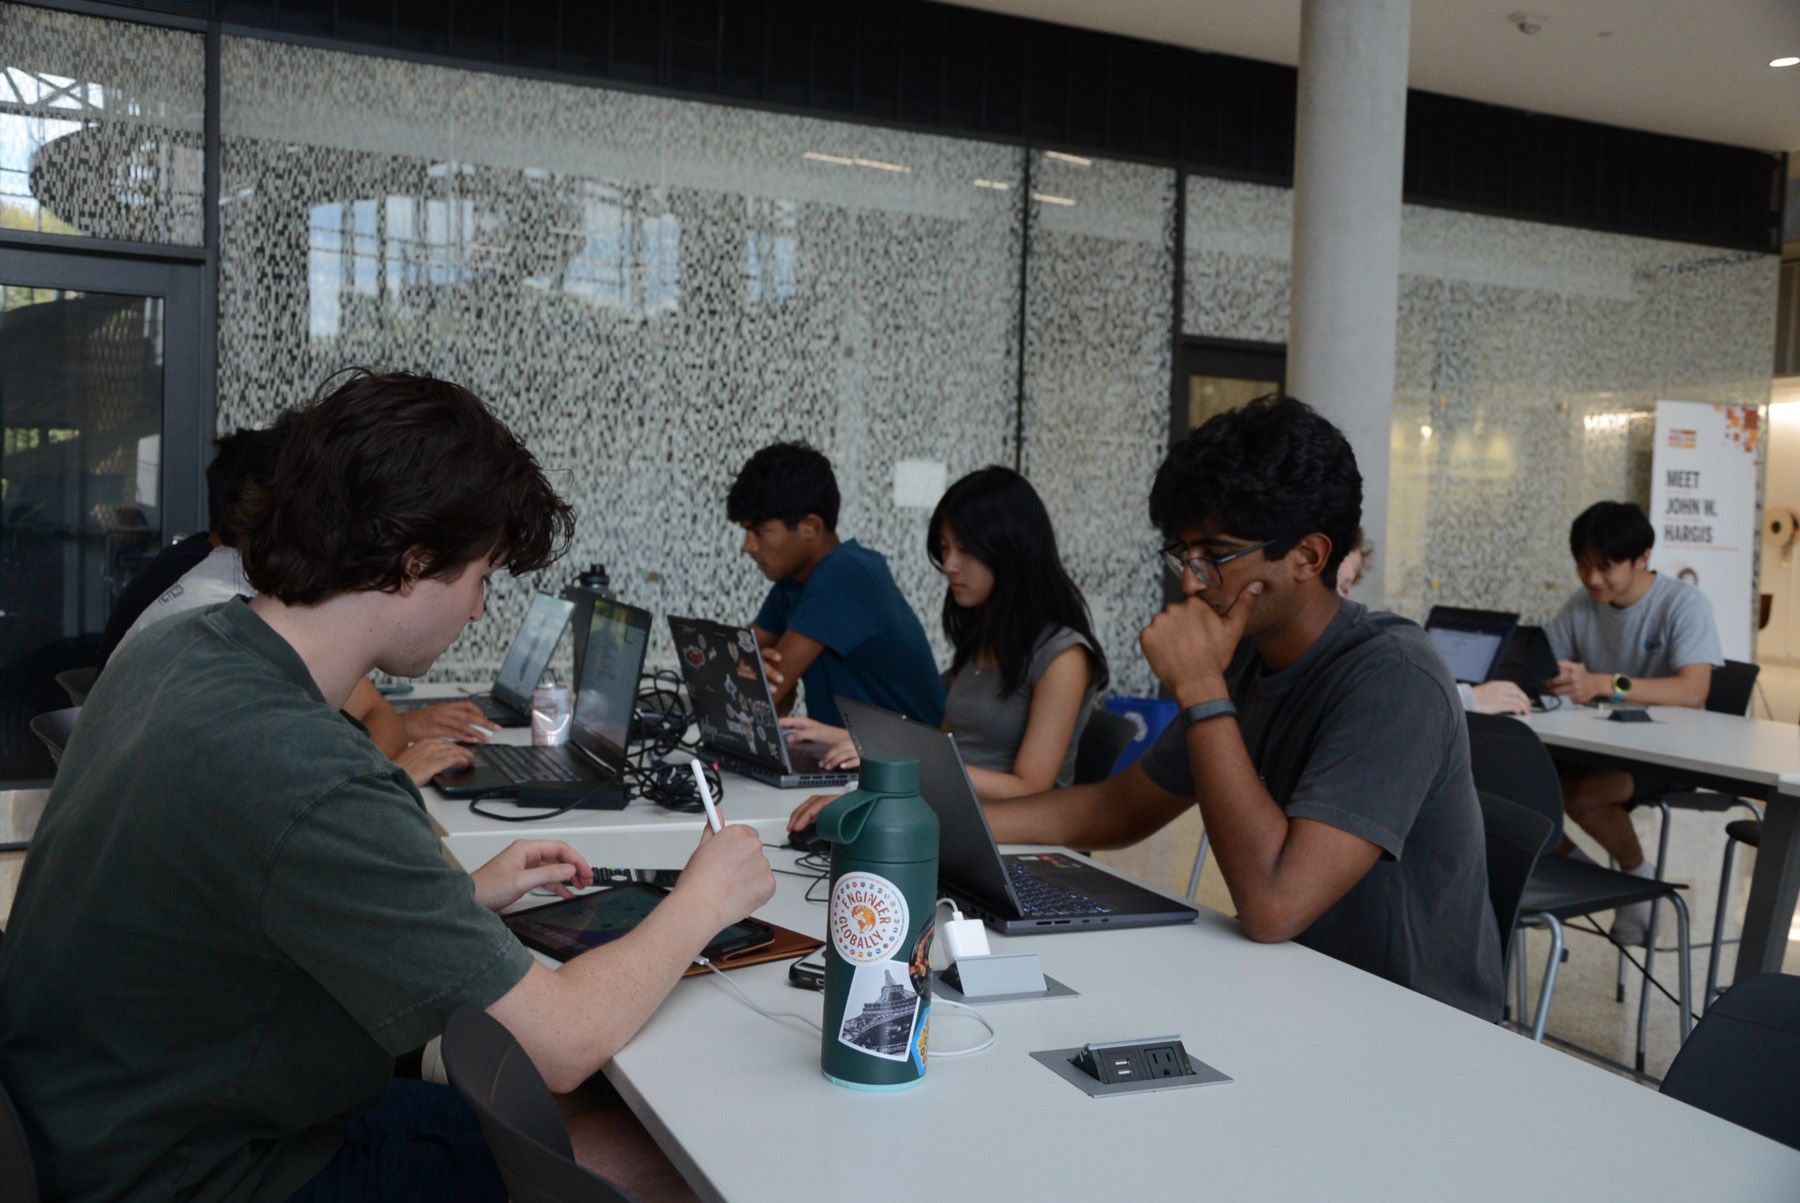
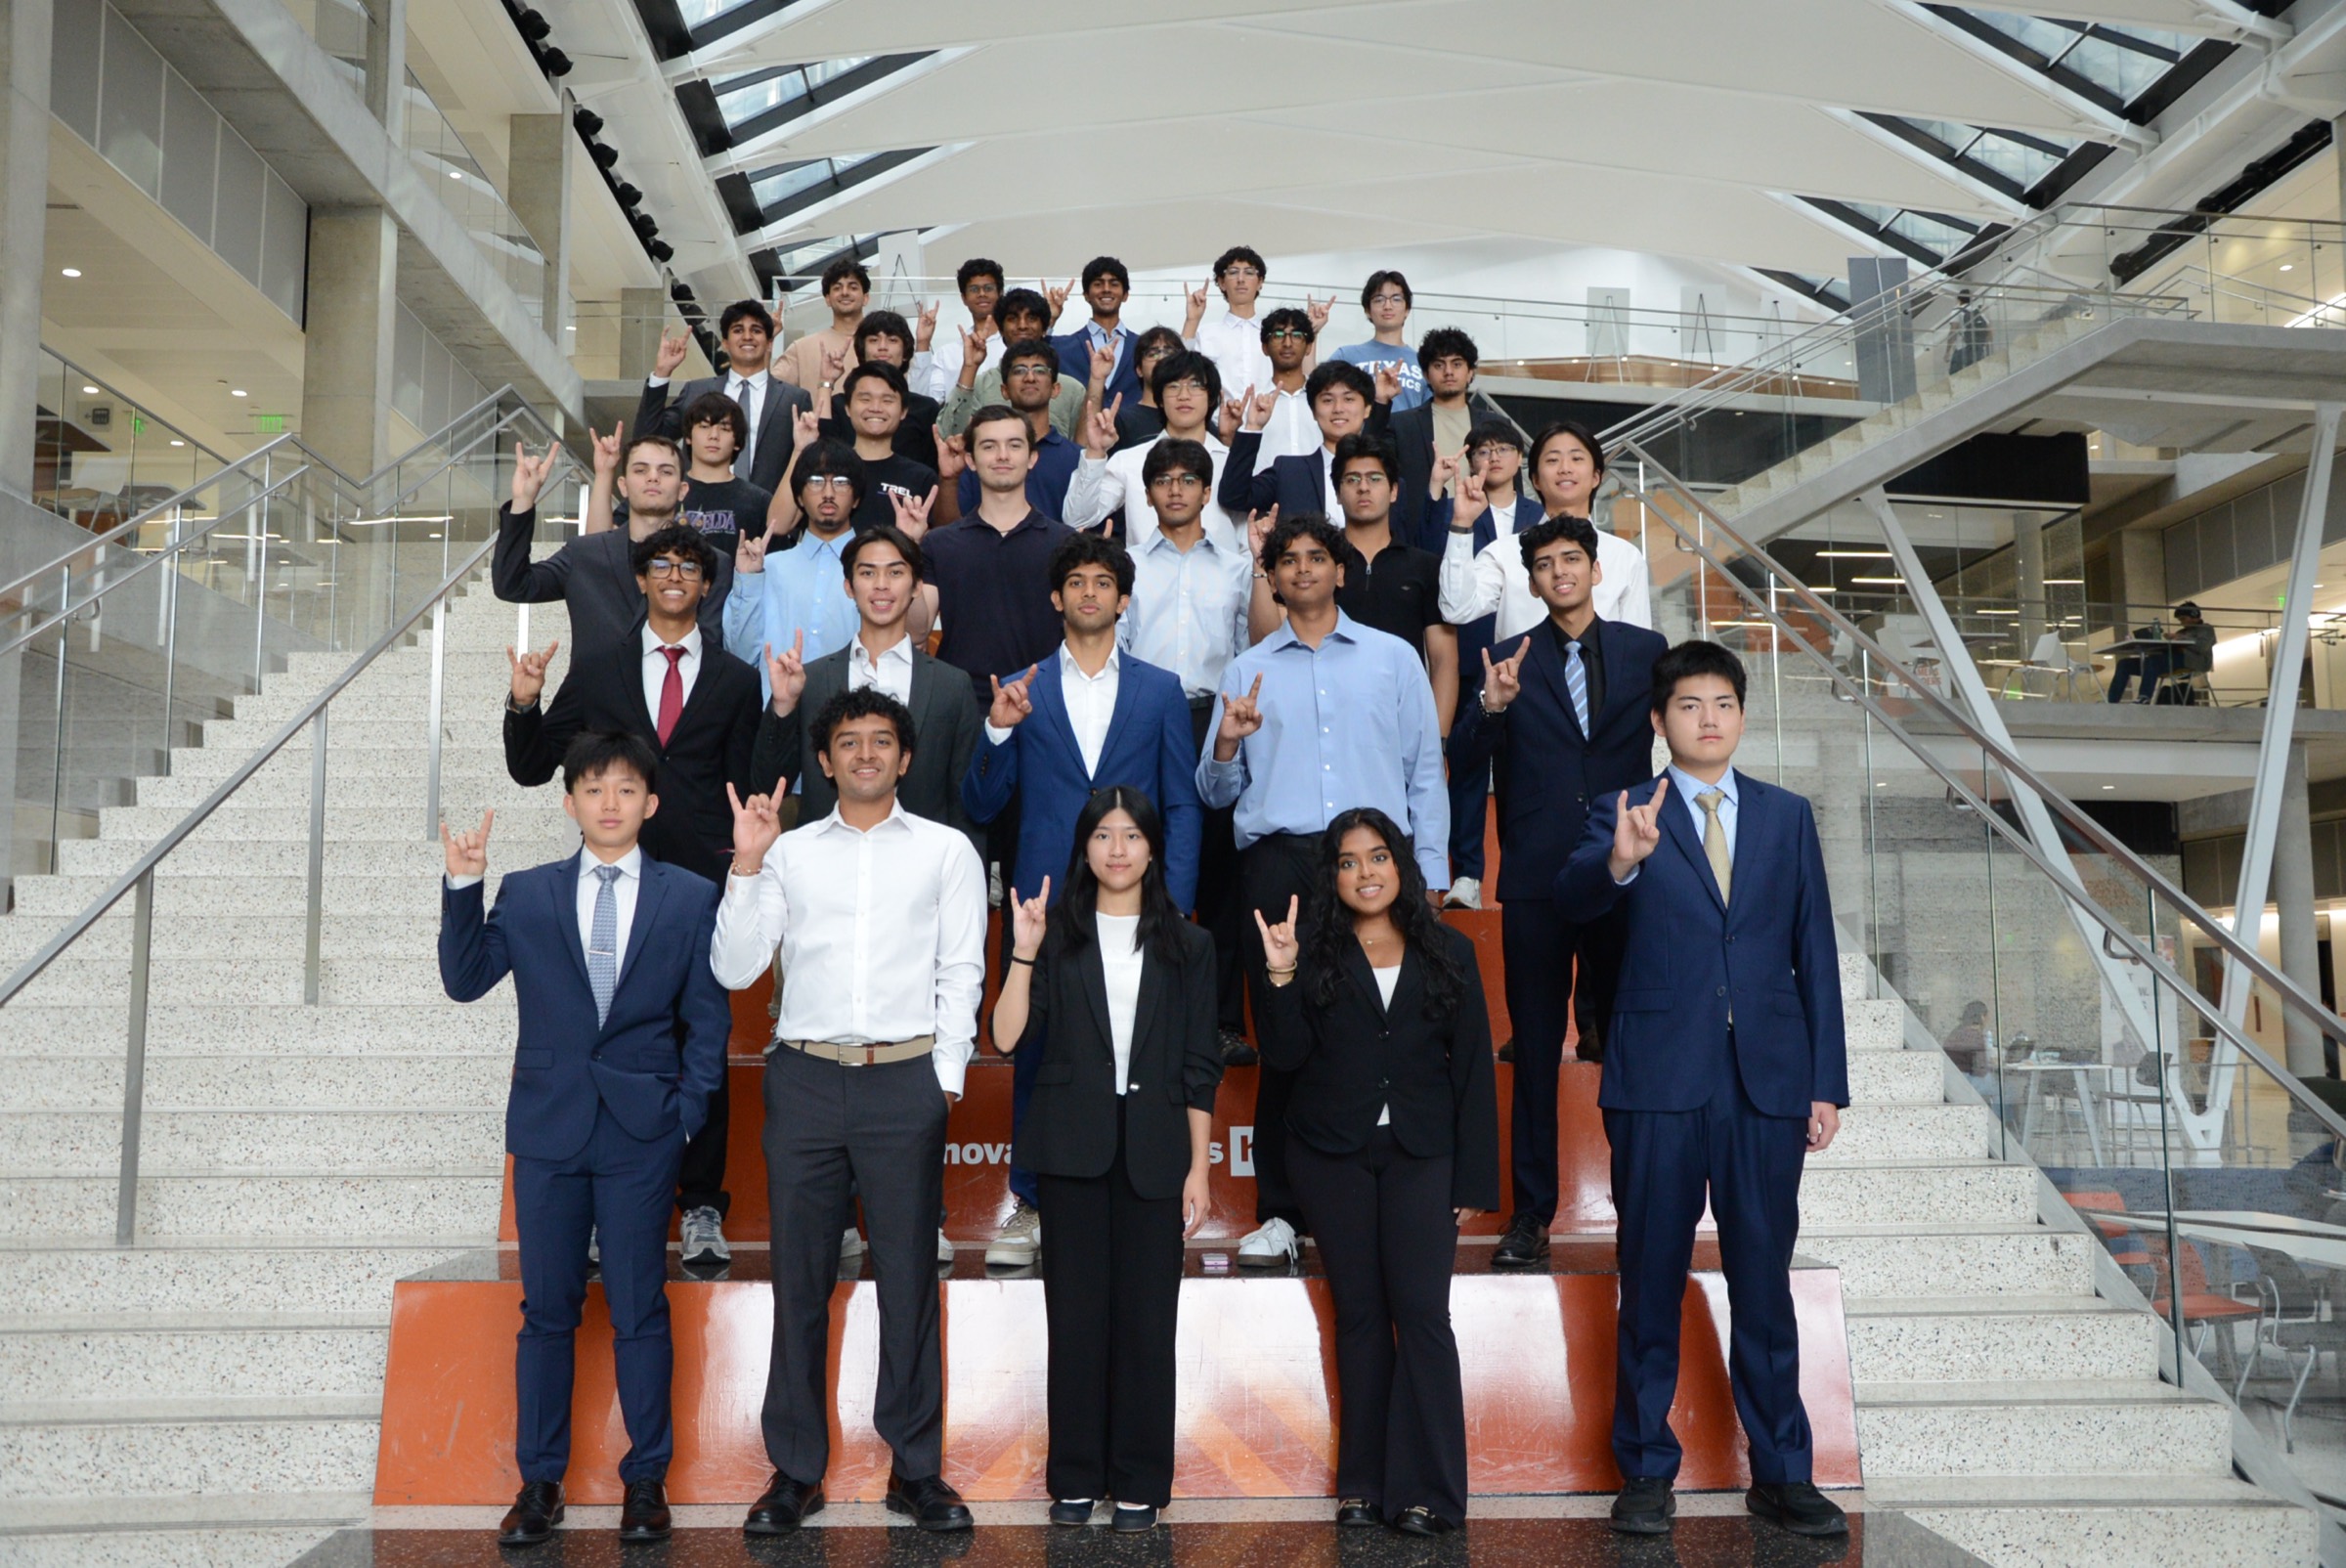
We build fast on purpose: short design-build-test loops, frequent subsystem reviews and a lot of hands-on debugging. It's unveiled in April 2027, and everything we learn carries straight into BevoBot.
- Type
- Open-source humanoid
- Role
- Baseline research platform
- Objective
- Autonomous walking
- Focus
- Actuators, simulation, controls, software
- Unveiling
- April 2027
- Status
- In development